
Xinyi Chen (Cindy)
I am a Ph.D. candidate at the Hong Kong University of Science and Technology (HKUST), advised by Prof. Shaojie Shen. Currently, I am a visiting researcher at the Mobile Robotics Lab in ETH Zurich, working with Prof. Stefan Leutenegger. Before that, I received a B.Sc. degree in Mathematics (Pure Mathematics Advanced Track) and in Computer Science from HKUST in 2021, when I have been exchanged to ETH Zurich in 2020 Spring.
🎓 I am expected to graduate in 2027 and actively exploring postdoctoral opportunities. If you are interested in collaboration, please feel free to contact me.
news
| Oct 14, 2026 | A comprehensive system work “RAVEN: A Unified Active SLAM System for Rapid Autonomous Visual Exploration with Aerial Robots under Localization Uncertainty” was conditionally accepted by IEEE Transactions on Robotics (T-RO). More details coming soon. |
|---|---|
| Apr 28, 2025 | An interesting paper Active Contact Engagement for Aerial Navigation in Unknown Environments with Glass was accepted by IEEE Robotics and Automation Letters (RA-L). Check out the video here. |
| Dec 25, 2024 | Our paper FALCON: Fast Autonomous Aerial Exploration Using Coverage Path Guidance was accepted by IEEE Transactions on Robotics (T-RO). |
| Mar 22, 2024 | We are thrilled that our ICRA2024 paper APACE was selected in IEEE Spectrum’s Video Friday: Your weekly selection of awesome robot videos! Check out the post here.  |
| Jan 29, 2024 | Our paper APACE: Agile and Perception-aware Trajectory Generation for Quadrotor Flights was accepted by 2024 IEEE International Conference on Robotics and Automation (ICRA2024). See you in Yokohama, Japan! |
selected publications
-
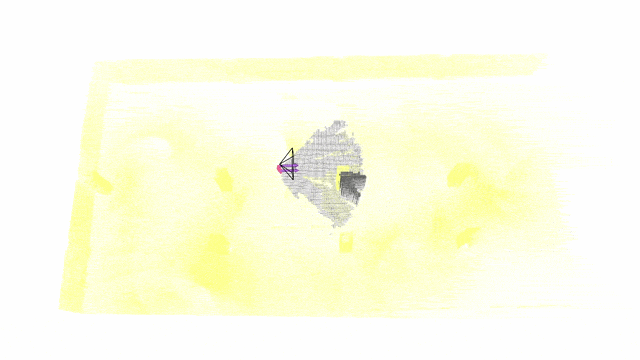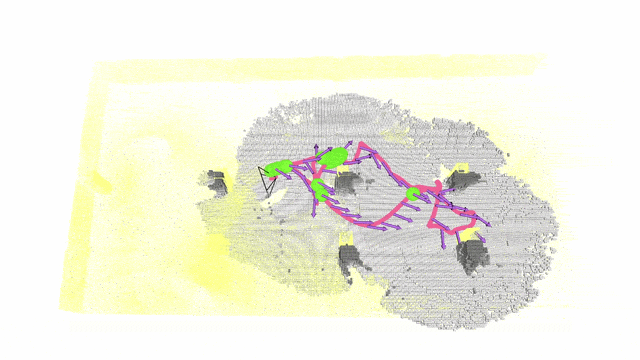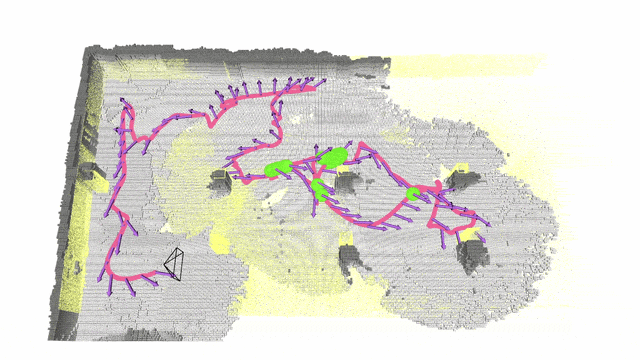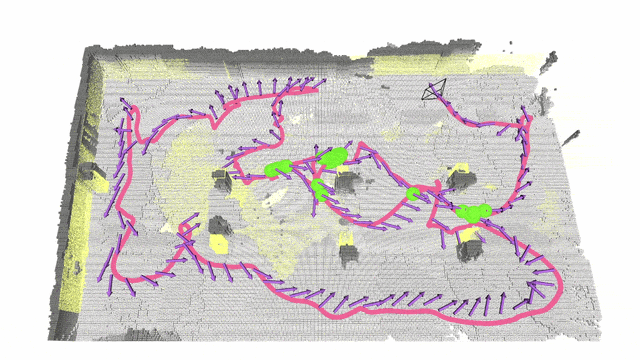 RAVEN: A Unified Active SLAM System for Rapid Autonomous Visual Exploration with Aerial Robots under Localization UncertaintyConditional acceptanceIEEE Transactions on Robotics (T-RO), 2026


